Custom Robotic Components for Sensor Mounts
Date:2026-09-29Article editor:Starting Point PrecisionViews:189Humanoid robots combine cameras, IMUs, force sensors, proximity sensors, and other sensing devices throughout their compact mechanical structures. These sensors require stable and accurately positioned mounting interfaces to support reliable operation. Custom-machined brackets, plates, housings, and adapter components provide a practical solution when standard mounting hardware cannot meet the mechanical requirements.
Custom Robotic Components for Sensor Mounts are precision-made mechanical parts designed to position and secure sensors within humanoid robot assemblies.
Humanoid robots have human-like body structures with moving joints, compact internal spaces, and multiple sensing points. Sensor mounting components may therefore require customized dimensions, unusual mounting angles, lightweight structures, and precise interfaces.
Typical components include:
● Sensor mounting brackets
● Camera mounting plates
● IMU mounting blocks
● Protective sensor housings
● Joint sensor brackets
● Adapter plates and interface components
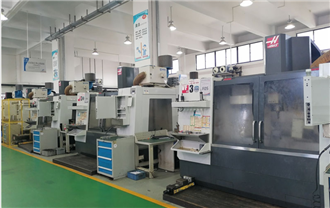
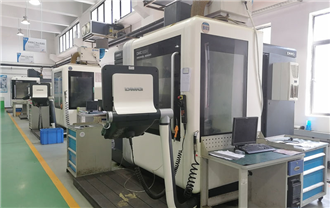
For customized CNC manufacturing requirements, Start Precision provides machining support for complex metal components and prototype-to-production projects.
Different parts of a humanoid robot may require different mounting solutions.
Head: Camera brackets and compact sensor housings must fit within limited space while maintaining stable positioning.
Torso: Mounting plates can integrate cameras, IMUs, communication modules, and other sensing devices with the robot's main frame.
Joints: Elbow, knee, wrist, and ankle sensor mounts require accurate interfaces while allowing surrounding mechanisms to move freely.
Hands and Feet: Smaller brackets may need lightweight construction and carefully positioned holes for sensors used in manipulation, balance, or contact detection.
A sensor mount is more than a simple support bracket. Its geometry can influence how accurately a sensor is physically positioned.
Important considerations include:
● Positioning accuracy: Critical mounting surfaces and hole patterns must match the design.
● Low weight: Material can be removed from non-critical areas when appropriate.
● Structural rigidity: The component should resist unwanted movement during operation.
● Interface accuracy: Locating surfaces, threads, and mounting holes need consistent dimensions.
● Cable clearance: The design should provide sufficient space for connectors and wiring.
● Surface requirements: Anodizing, passivation, or other finishing may be selected according to the application.
Our machining strategy is developed around the component's functional requirements rather than using one fixed process for every part.
1. CAD Requirement Analysis
We review the 3D model and drawing to identify sensor interfaces, locating surfaces, hole relationships, wall thickness, and critical tolerances.
A suitable reference system is established before machining. Workholding is planned to maintain the relationship between critical features and reduce unnecessary repositioning.
CNC milling and turning are selected according to the geometry. Small holes, threaded features, pockets, angled surfaces, and sensor reference faces can be machined according to the drawing requirements.
After machining, sharp edges are removed and the specified surface treatment can be applied. For aluminum components, anodizing may be considered when surface protection and appearance are required.
Critical dimensions, hole locations, interfaces, and overall geometry are checked against the approved design before the parts are released.
Material selection depends on the robot's structural and weight requirements.
● Aluminum alloys: Suitable when low weight and good machinability are important.
● Stainless steel: Useful when higher corrosion resistance or strength is required.
● Titanium alloys: Considered for applications requiring high strength with controlled weight.
● Engineering plastics: Useful for selected lightweight or electrically isolated components.
A humanoid robot project required a compact CNC-machined camera mount for the head assembly. The original design needed several mounting holes, a precise sensor interface, cable clearance, and low overall weight.
We focused machining control on the sensor reference face and hole positions while using pocket features to reduce unnecessary material. After deburring and dimensional inspection, the finished bracket could be integrated with the camera assembly without modifying the robot's surrounding structure.
This approach allows the mounting component to be developed around the actual sensor and robot interface rather than relying on a generic bracket.
Humanoid robot development often involves frequent design revisions and changing sensor configurations. CNC machining allows manufacturers to produce customized geometries while maintaining consistent interfaces between different production batches.
For prototypes, engineering samples, and low-to-medium volume production, a controlled machining process can also simplify the transition from development to repeat manufacturing.
Visit Start Precision to discuss your customized robotic component requirements.
Contact us to discuss your manufacturing needs.
1. What types of sensor mounts can be manufactured for humanoid robots?
We can manufacture custom brackets, mounting plates, sensor housings, adapter blocks, joint sensor mounts, and other CNC-machined interfaces according to drawings or CAD models.
2. Which materials are commonly used for sensor mounts?
Aluminum alloys are widely considered for lightweight structures. Stainless steel and titanium can be selected when higher strength or specific environmental properties are required.
3. Can complex sensor mounting geometries be CNC machined?
Yes. CNC milling, multi-axis machining, precision drilling, tapping, pocketing, and other operations can be combined according to the geometry.
4. Can you manufacture prototype humanoid robot components?
Yes. Custom parts can be produced for prototypes, engineering validation, and subsequent low- or medium-volume production.
5. Why are sensor mounting tolerances important?
The mounting interface determines the physical position and orientation of the sensor. Controlled dimensions help maintain consistent mechanical integration with the robot assembly.
Add: Building 3No.277 Zhen'an Middle Road, Chang'an Town,Dongguan,Guangdong, China
Tel:+86-769-82855591
Copyright © 2019 All Rights Reserved Dongguan Start Precision Technology Co., Ltd. Tel: +86-769-82855591
Add: No. 277 Zhen'an Middle Road, Chang'an Town, Dongguan, Guangdong, China
 中文版
 English